A robot arm that picks up a cup, hands it to a person, and lets go: all triggered by hand gestures. Built on top of the Viam Vision-Guided Pick-and-Place workshop, on a uFactory xArm6 with a wrist-mounted Intel RealSense depth camera.
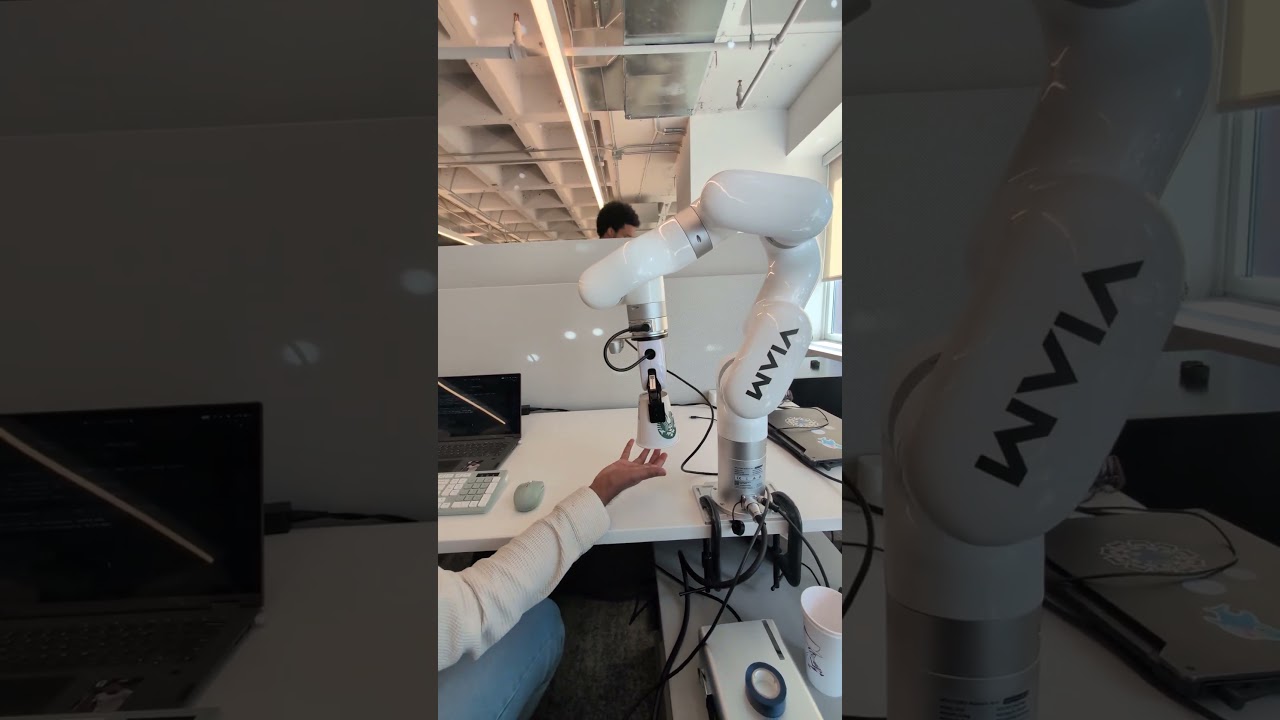
(click the thumbnail to watch on YouTube)
- Wait for a pick gesture — the arm sits at a home pose watching the camera until it sees a right-hand thumbs up.
- Detect the cup — moves to a fixed cup-view pose, segments the cup from the scene, and reconstructs its point cloud in the world frame.
- Estimate geometry — fits a circle to the cup's rim (falling back to a silhouette estimate if the rim isn't fully visible) to find its axis, radius, and height.
- Grasp — plans a top-down approach, descends in a straight line to just below the rim, and closes the gripper.
- Hand over — lifts the cup, moves to an end pose, and waits for a release gesture before opening the gripper. If nobody takes the cup in time, it's placed back where it was picked up.
All of this lives in pick-and-place/scripts/cup-grasp.py.
.
├── README.md                        # this file
└── pick-and-place/                  # workshop scaffold this project builds on
    ├── config/                      # reference machine config + safety-wall obstacles
    ├── scripts/
    │   ├── cup-grasp.py             # this project: gesture-triggered cup pick + handover
    │   ├── reference-solution.py    # workshop reference: block pick-and-sort
    │   ├── starter-script.py        # workshop starting point with TODOs
    │   └── module-reference.py      # notes on the arm-position-saver / obstacle modules
    └── setup/
        └── frame-calibration-worksheet.md
See pick-and-place/README.md for the full
workshop background, hardware list, and machine setup steps.
cd pick-and-place/scripts
uv sync
export VIAM_MACHINE_ADDRESS=<your machine address>
export VIAM_API_KEY=<your api key>
export VIAM_API_KEY_ID=<your api key id>

uv run python cup-grasp.py                        # dry run — prints the plan, doesn't move
uv run python cup-grasp.py --execute               # approach, grasp, lift
uv run python cup-grasp.py --execute --handover     # ...then hand the cup to a person
Useful flags:
| Flag | What it does |
|---|---|
--execute |
Actually move the arm (default is a dry run) |
--handover |
After lifting, go to the end pose and wait for a release gesture |
--no-release |
Rehearse a handover without ever opening the gripper |
--stop-after approach|grasp|lift |
Stop early, useful for tuning |
--print-joints |
Print current joint angles (for setting START_JOINTS_DEG) |
--watch-gestures |
Print gesture-detector output for 60s without moving the arm |
--dump <csv> |
Save the detected cup's world-frame point cloud for inspection |
Before running --execute near people or equipment, check the printed
grasp plan against the scene and tune the constants at the top of
cup-grasp.py (grasp depth, standoff, gripper length offset, gesture
thresholds) for your hardware.
| Component | Role |
|---|---|
| uFactory xArm6 | 6-DOF arm |
| uFactory finger gripper | End effector |
| Intel RealSense D435 | RGB + depth camera, wrist-mounted |
| System76 Meerkat | Robot computer running viam-server |
Built at a Viam hackathon on top of Viam's Vision-Guided Pick-and-Place workshop.